
VLA-Robot Motion Control Development Platform
Release time:2026-06-03 09:33:52
The CT-Unite Robotics Motion Control Development Platform is a new-generation robotic "cerebellum" development platform built on the CT-2001A motion control chip from Zhongke Semiconductor and the CT-190X series gallium nitride (GaN) driver chips. This platform deeply integrates with the internationally leading VLA universal model architecture, focusing on core pain points in robotic motion control. It covers all scenarios of cutting-edge academic-industry research innovation, teaching training, and enterprise product mass production, offering a comprehensive, practical, and scalable full-chain development solution—from low-level hardware drivers and mid-level algorithms to high-level global dynamics control. It empowers developers to overcome industry bottlenecks such as insufficient robotic control precision, poor dynamics adaptability, low joint energy efficiency, multimodal data misalignment, and lengthy development cycles.
Through this platform, developers can simulate issues such as kinetic energy loss, design flaws, algorithm adaptation, dynamic simulation, joint heat dissipation optimization, phonon energy transfer simulation design, and multimodal technology fusion data alignment in robot joint motion control. The hardware can accurately match the universal "VLA model".
Relying on the open-source motion control technology ecosystem of Zhongke Semiconductor, the platform supports rapid optimization and iterative upgrading of underlying algorithms such as FOC vector control and PID high-precision servo closed-loop. The model predictive control (MPC) algorithm for robot control core can efficiently solve the multi variable strong coupling problem during the motion process, accurately compatible with complex physical boundary conditions such as joint motion limits, contact force thresholds, and velocity acceleration constraints, and achieve stable, high-precision, and predictable dynamic servo control universal algorithm optimization.
At the same time, the platform supports multi device networking and low latency linkage, and builds a distributed real-time control network by connecting multiple development platforms in series, perfectly replicating the logic of robot whole body control (WBC). It can standardize high-dimensional and highly redundant robot full body multi task collaborative control problems into quadratic programming (QP) solving problems, and support custom task priority strategies (such as posture balance, walking motion, end effector execution, and other multi-level priority configurations), intelligently resolving multi task conflicts. On the premise of strictly satisfying mechanical structure and physical motion constraints, the platform can achieve full body coordination, dynamic stability, high-precision simulation verification, and algorithm implementation of robots, covering mainstream high-end robot control algorithm development scenarios such as ZMP zero torque point, MPC, WBC, etc.
2、 Hardware development aspect
Relying on the CT-2001A and CT-190X series high-performance gallium nitride driver chips for robots, it has the advantages of high switching frequency, low on resistance, and small size, bringing revolutionary improvements in robot power output. Simulate the voltage overshoot and switch loss issues caused by parasitic inductance on joint circuit boards of different sizes in the later stage through this hardware platform. By comparing these test data, it plays a crucial role in reducing loop thermal resistance, minimizing joint heat generation, and promoting energy-efficient design for customized high-efficiency miniaturized "joint" actuators in the later stage. At the same time, it shortens the time for product development and market launch.
3、 Technical advantages
1. With smaller volume and weight, users can develop more compact and lightweight robot joint modules, directly improving the mobility and load capacity of the robot.
2. Higher efficiency and lower heat loss significantly reduce power consumption and heat generation, resulting in longer robot endurance, simpler heat dissipation design, and more stable system.
3. By relying on the high-frequency switching characteristics of the chip and optimized FOC and MPC control algorithms, a comprehensive and precise closed-loop control of motor torque, speed, and position is achieved, effectively suppressing low-speed shaking and abnormal noise during operation, greatly improving the smoothness of robot motion and operational accuracy.
4. The high degree of integration and modularization significantly reduces the development threshold and cycle, and the design philosophy of the development board greatly considers usability.
5. Rapid prototyping development, developers do not need to design complex core circuits from scratch, but only need to focus on the sensors, actuator interfaces, and upper level algorithms related to their own robots, "plug and play", shortening the development cycle from "year" to "month". Standardized VLA model adaptation, compatible with mainstream high-end algorithm systems. Native benchmark general VLA dynamic model, perfectly adapted to mainstream high-end robot algorithms such as MPC model predictive control, WBC whole body control, ZMP stable control for simulation, development, and performance evaluation, achieving algorithm standardization, portability, and mass production.
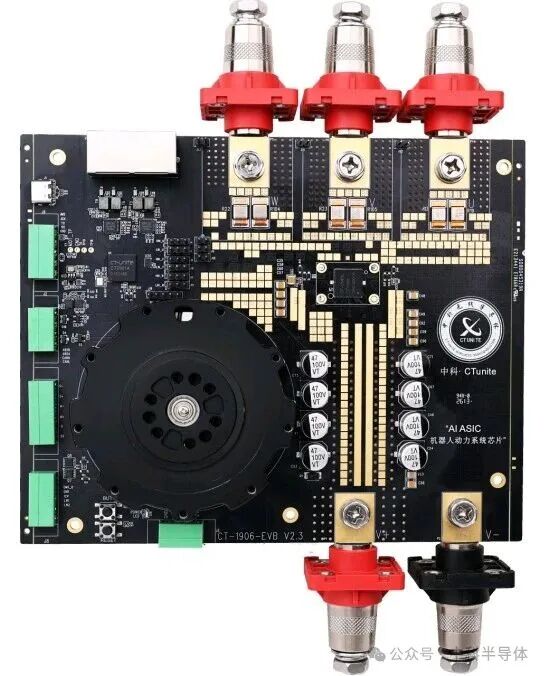
The Zhongke Robot Power System Chip Development Platform technology has achieved real-time control of VLA models and delivered them to developers in a user-friendly manner. Make it an efficient simulation tool for robot developers to break through the bottleneck of robot motion control algorithms and "joint" actuator performance, and quickly realize innovative ideas. You can also leverage the existing open-source motion control model capabilities of Zhongke Semiconductor to experience the charm and experience brought by the new generation of AI ASIC chips for robots in developing the next generation of VLA model adaptation.
Announcement on Industry University Research Collaboration:
We cordially invite university researchers, teachers, and students to participate in technological breakthroughs, problem unveiling, and collaborative innovation between industry, academia, and research. Based on the "Robot Motion Control Development Platform", multiple gradient cash rewards are set up to focus on incentivizing key technological innovations and breakthroughs in fields such as FOC, MPC, ZMP, WBC, ToF, DVS, machine vision, dynamic algorithms, and multimodal algorithm fusion neural networks. This helps students to be exposed to the forefront of the industry and the entire process of enterprise robot development during their school years, synchronize with real R&D scenarios of enterprises, effectively shorten the distance between campus learning and industry demand, and grow into cutting-edge technology talents in the field of robot development that are in short supply.
To obtain cooperation information and technical materials, please contact:
Email: sales1@ctunite.com (Note "Robot Motion Control Development Platform")